Propagation
For input units \([u]\), Propagation is the \(K\)-channel current-form propagation
operator used by LineDistributed. It applies a fitted input factor, one scalar
delay per mode, and a fitted output factor while preserving the input units.
With \(\mathbf G_\mathrm{in}\) and \(\mathbf G_\mathrm{out}\) the transfer matrices of the input and output factors,
Block Diagram
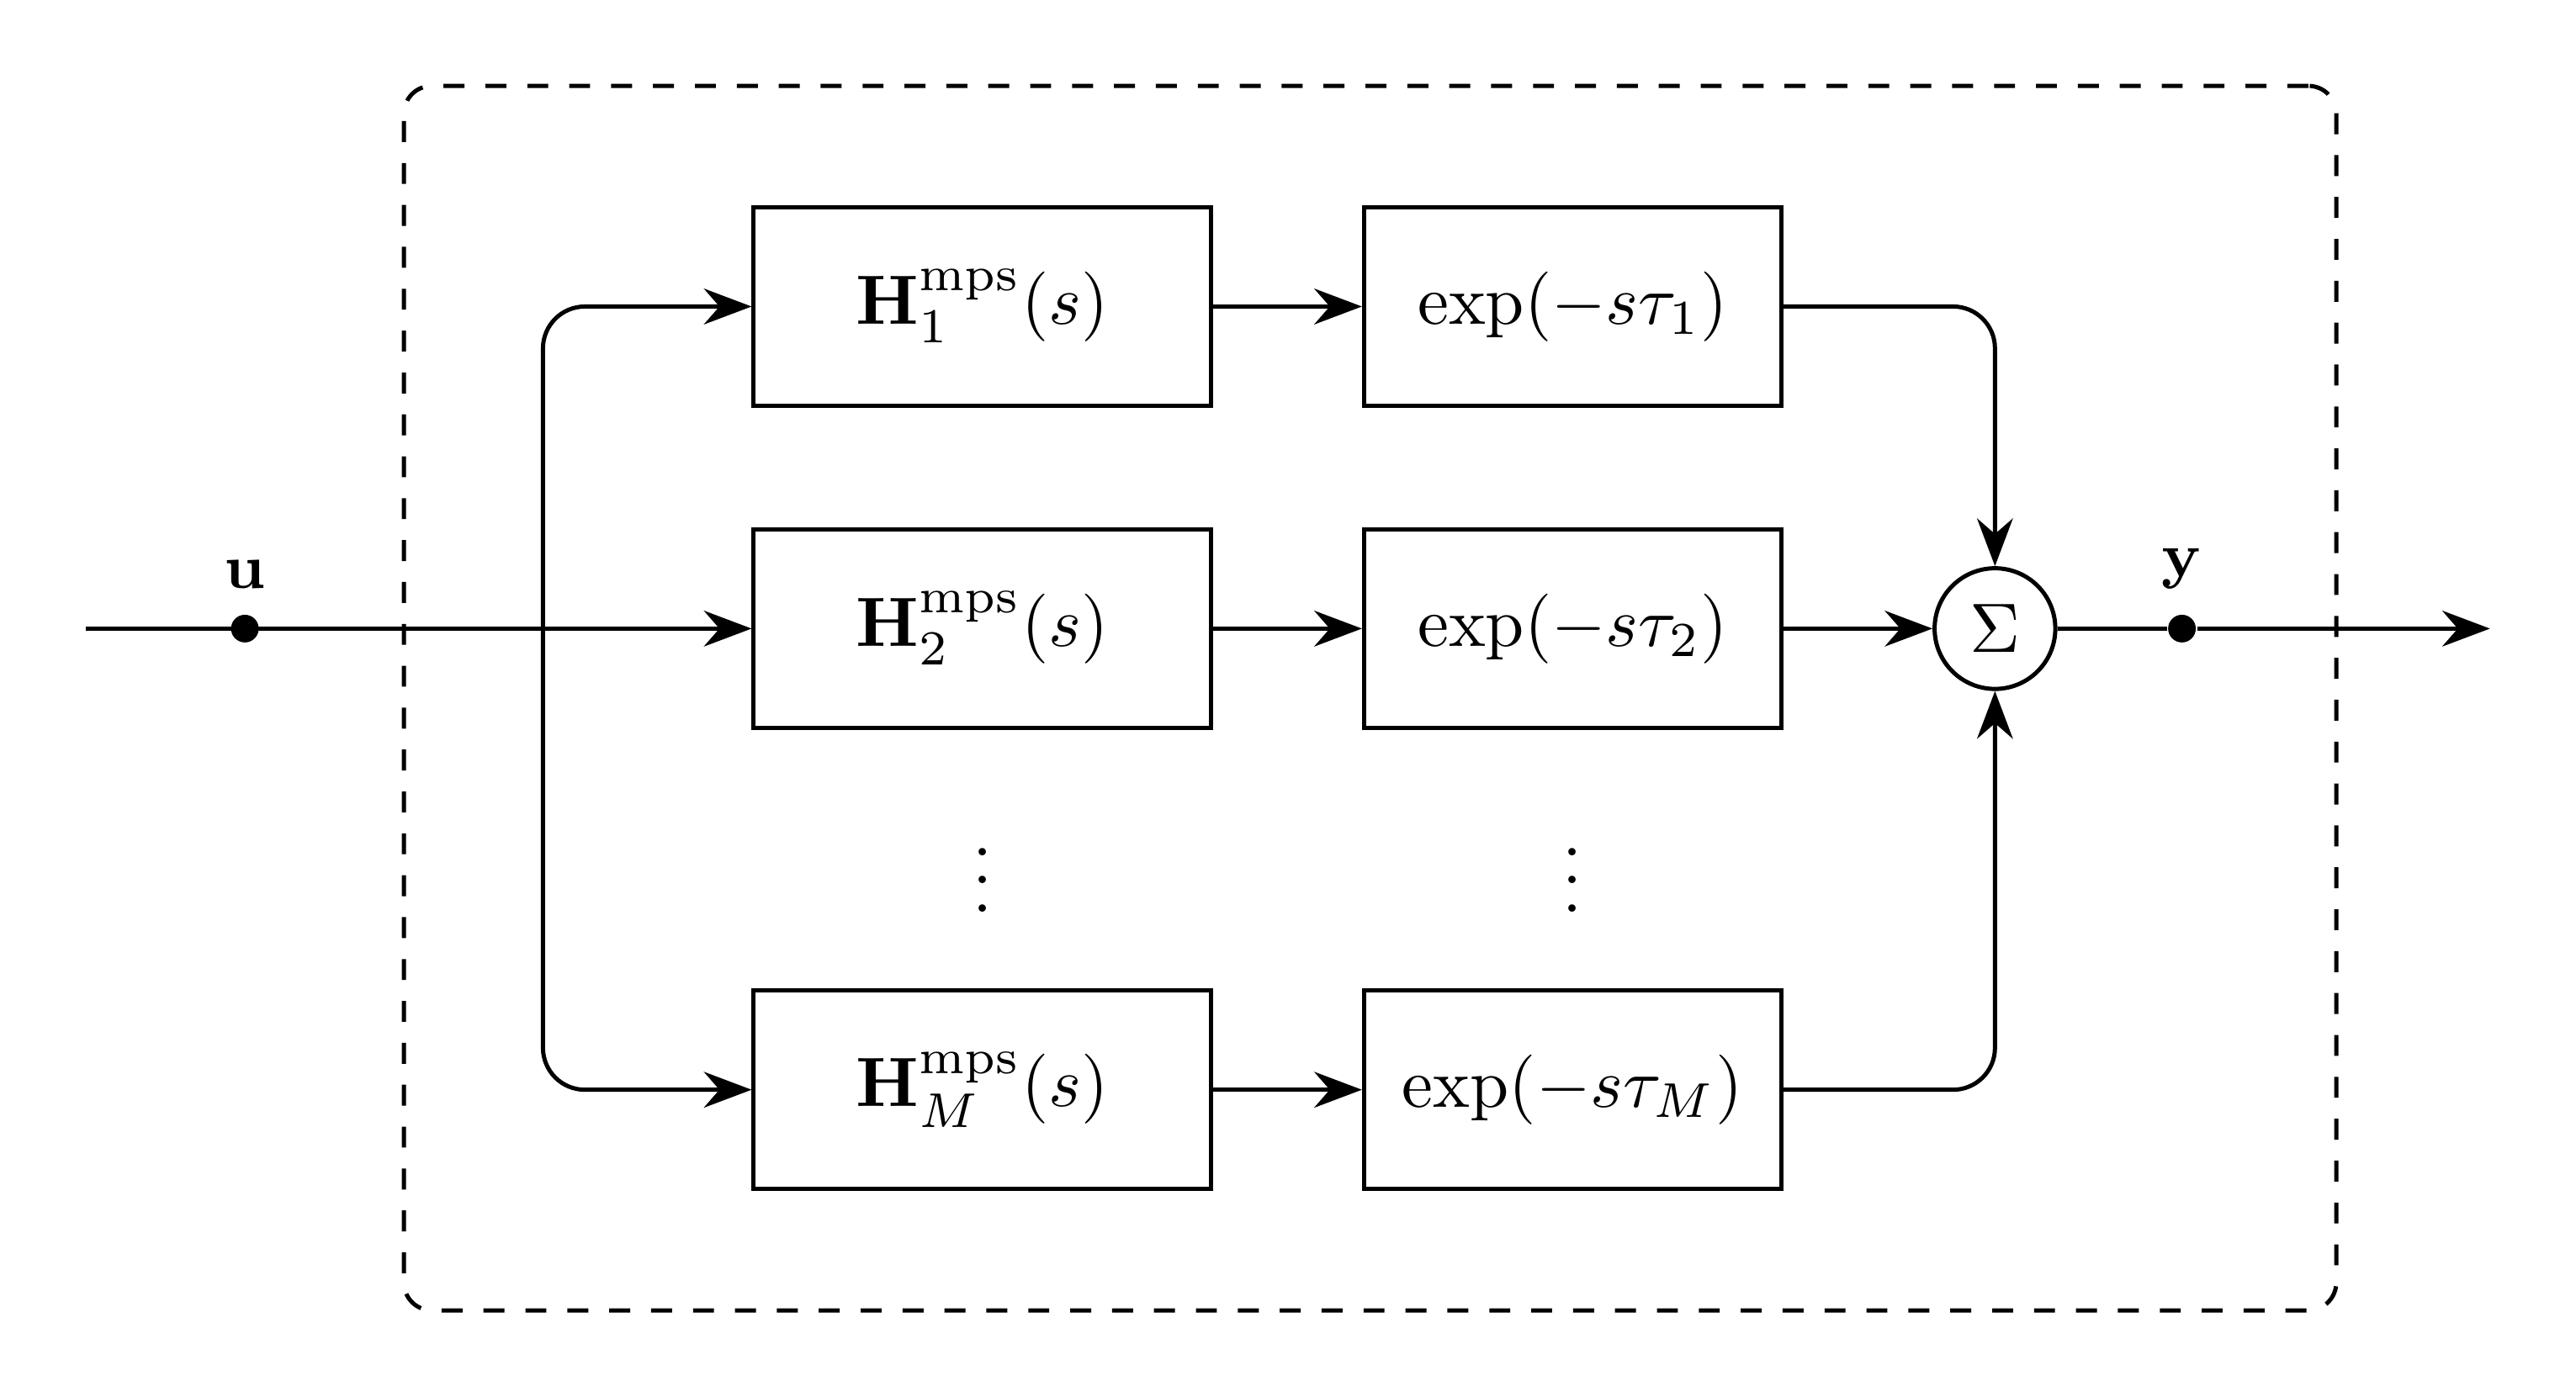
Figure 1: Propagation model
Model Parameters
Symbol |
Units |
JSON |
Description |
Note |
|---|---|---|---|---|
\(K\) |
[-] |
|
Signal dimension |
Required, positive integer |
Parameter Validation
Model Derived Parameters
The full modal basis has one mode per channel:
The modal delays are produced by the offline propagation fitting and enter
through the delay bank’s delays coefficient set.
Model Ports
Symbol |
Port |
Type |
Units |
Description |
Note |
|---|---|---|---|---|---|
\(\mathbf{u}\) |
|
Input |
\([u]\) |
Input vector port |
\(\mathbf{u} \in \mathbb{R}^K\) |
\(\mathbf{y}\) |
|
Output |
\([u]\) |
Output vector port |
\(\mathbf{y} \in \mathbb{R}^K\) |
Submodels
Symbol |
Description |
Type |
Order |
JSON |
Inputs |
Outputs |
|---|---|---|---|---|---|---|
\(\mathbf{g}_\mathrm{in}\) |
Input factor |
\(KQ_{\mathbf{g}_\mathrm{in}}\) |
|
\(\mathbb{R}^K\) |
\(\mathbb{R}^M\) |
|
\(\mathbf{d}\) |
Modal delay bank |
History |
|
\(\mathbb{R}^M\) |
\(\mathbb{R}^M\) |
|
\(\mathbf{g}_\mathrm{out}\) |
Output factor |
\(KQ_{\mathbf{g}_\mathrm{out}}\) |
|
\(\mathbb{R}^M\) |
\(\mathbb{R}^K\) |
Submodel Validation
Both rational factors must have stable poles and no term linear in \(s\). The input factor has algebraic input; the output factor has differential input from the modal delay bank.
Submodel Wiring
Model Variables
Internal Variables
Differential
None.
Algebraic
None.
External Variables
Differential
None.
Algebraic
Symbol |
Units |
Description |
Note |
|---|---|---|---|
\(\mathbf{u}\) |
\([u]\) |
Input vector |
\(\mathbf{u} \in \mathbb{R}^K\) |
Model Equations
Internal Equations
Differential
None.
Algebraic
None.
External Equations
Initialization
Initialize the rational factors using the EMT initialization contract. Provide the input-factor output history required by Delay.
Monitors
None.